Problem
A mobile robot can lose its ability to recover safely before an immediate collision warning. Localisation uncertainty, ageing measurements and delayed commands must be considered together.
Architecture
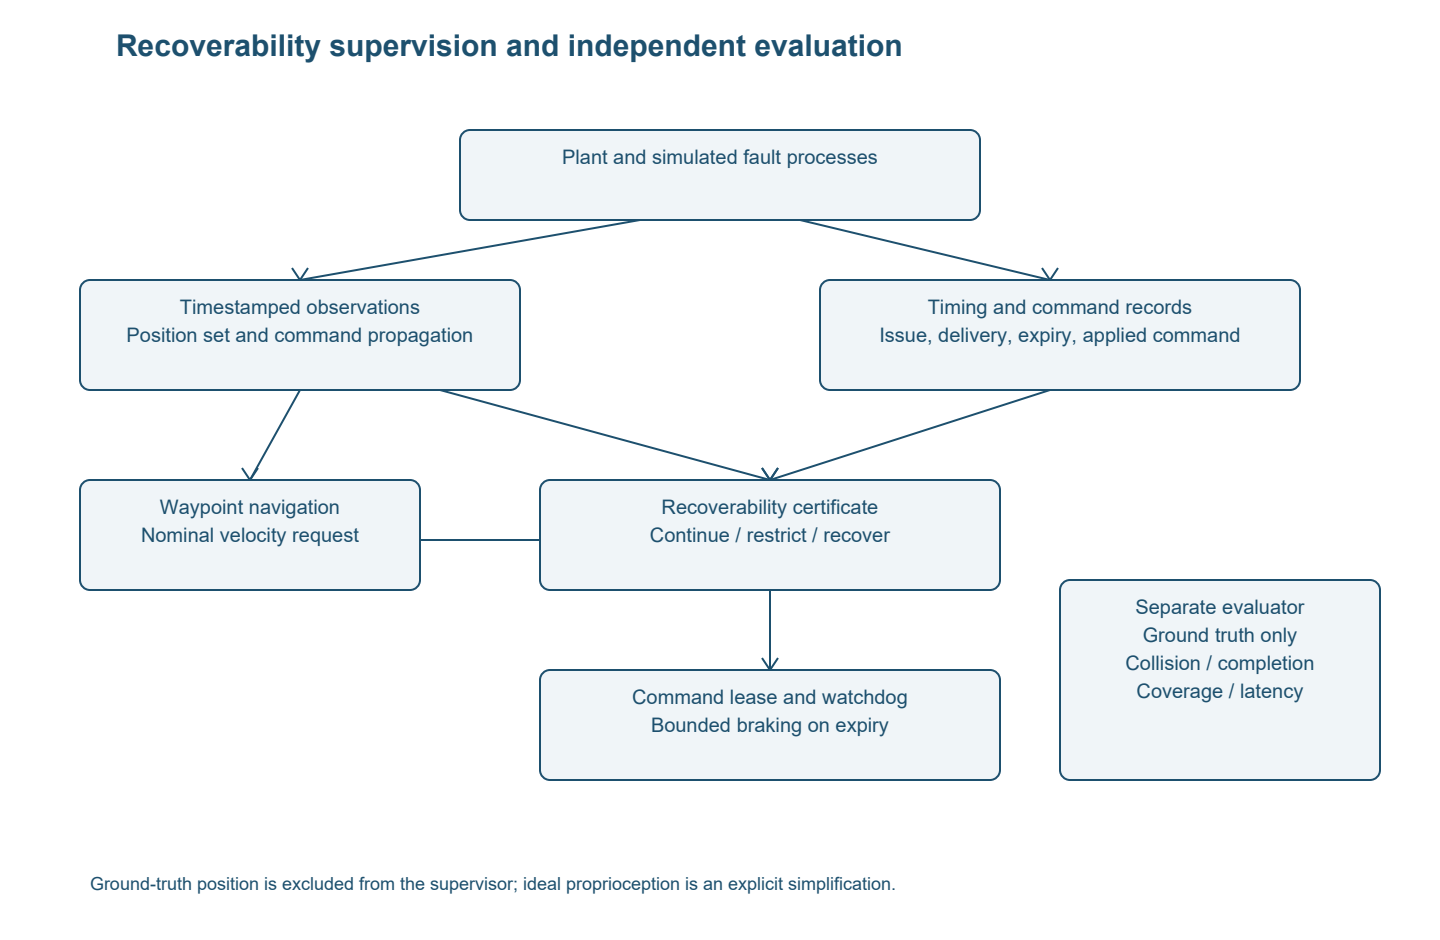
Timestamped observations and command records form a bounded position estimate. A recovery certificate combines uncertainty, geometry, response delay and braking capability to select continue, restrict or recover. Command leases and a separately scheduled watchdog trigger braking when an approved command expires.
Design decisions
- 01Preserved a feasible braking manoeuvre through a state-dependent clearance envelope and admissible-speed limit.
- 02Propagated measurement age and outstanding commands into the recovery calculation.
- 03Kept the simulated plant moving during delayed computation and compared matched fault schedules across six supervisor variants.
- 04Evaluated learned anticipation separately from the model-based safety certificate.
Verification
Evaluated 100,000 sampled boundary states, 32,400 navigation episodes, 3,900 supplementary episodes, 24,000 wall approaches and four process-based timing cases. Joint supervision completed 5,268 of 5,400 navigation episodes versus 2,674 for a global worst-case supervisor. Both recorded zero collisions in 3,000 bounded wall approaches; beyond-bound tests exposed failures when braking or response-delay assumptions were violated. The study uses a reduced-order model and static obstacles.