Robotics
SPC-001 Waterless Solar-Panel Cleaner
A modular waterless solar-panel cleaning robot combining a tracked platform, dry-cleaning roller, electronic interfaces and supervisory control. I have built and tested the hardware, and it is operating as intended.
The challenge
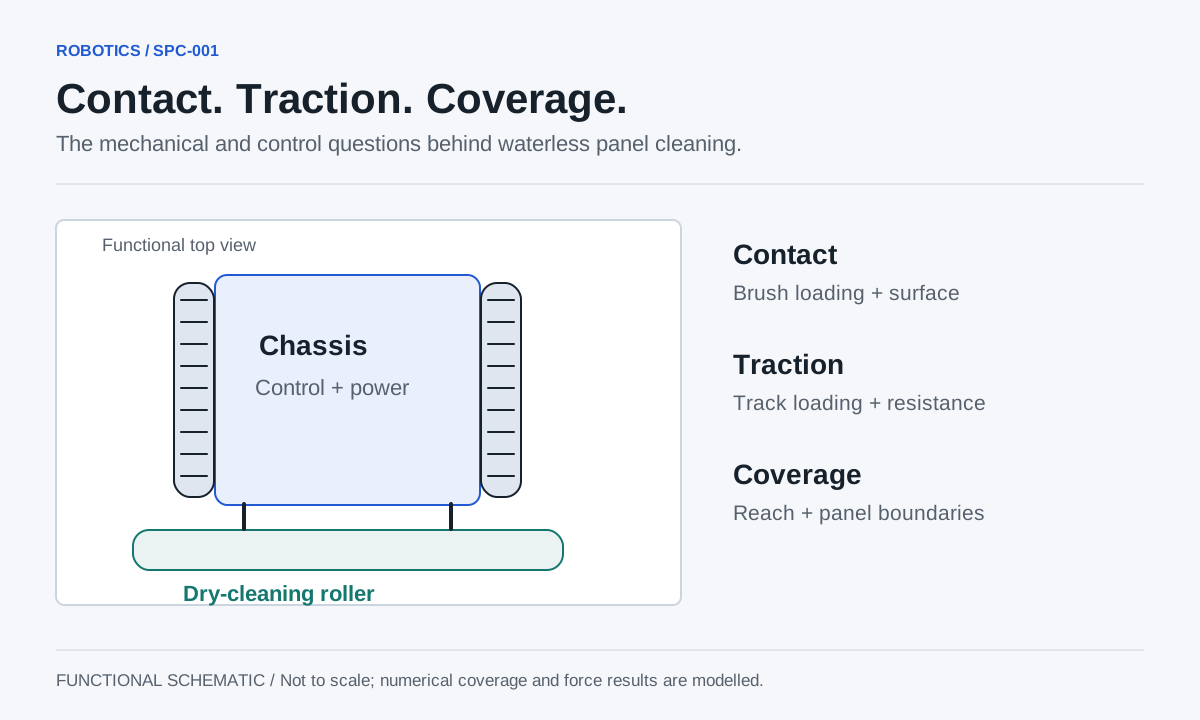
Cleaning solar panels without water couples surface contact, traction, cleaning reach and motion control.
How the system works
The mechanical design separates the chassis, track pods and cleaning roller, with docking and loading interfaces. Supervisory control manages operating states and fault handling, while the analytical work examines contact forces, drive torque, energy and coverage geometry.
Design decisions
- Considered brush loading and traction together because cleaning contact changes both resistance and available track loading.
- Examined the trade-off between keeping the platform inside a panel boundary and allowing the brush to reach its edges.
- Kept mechanical modules and control interfaces explicit to support inspection, maintenance and further development.
What the evidence shows
The hardware has been built and functionally tested. The paper separately presents reproducible analytical calculations and archived software checks: 40,184 supervisor assertions and 870 coverage-planner assertions. Numerical force, torque, energy and coverage figures are modelled results.
Research publication
Engineering case study
Go deeper into the design choices, tests and lessons from the project.
Read the SPC-001 Waterless Solar-Panel Cleaner case study